Microduck
by Pollen Robotics
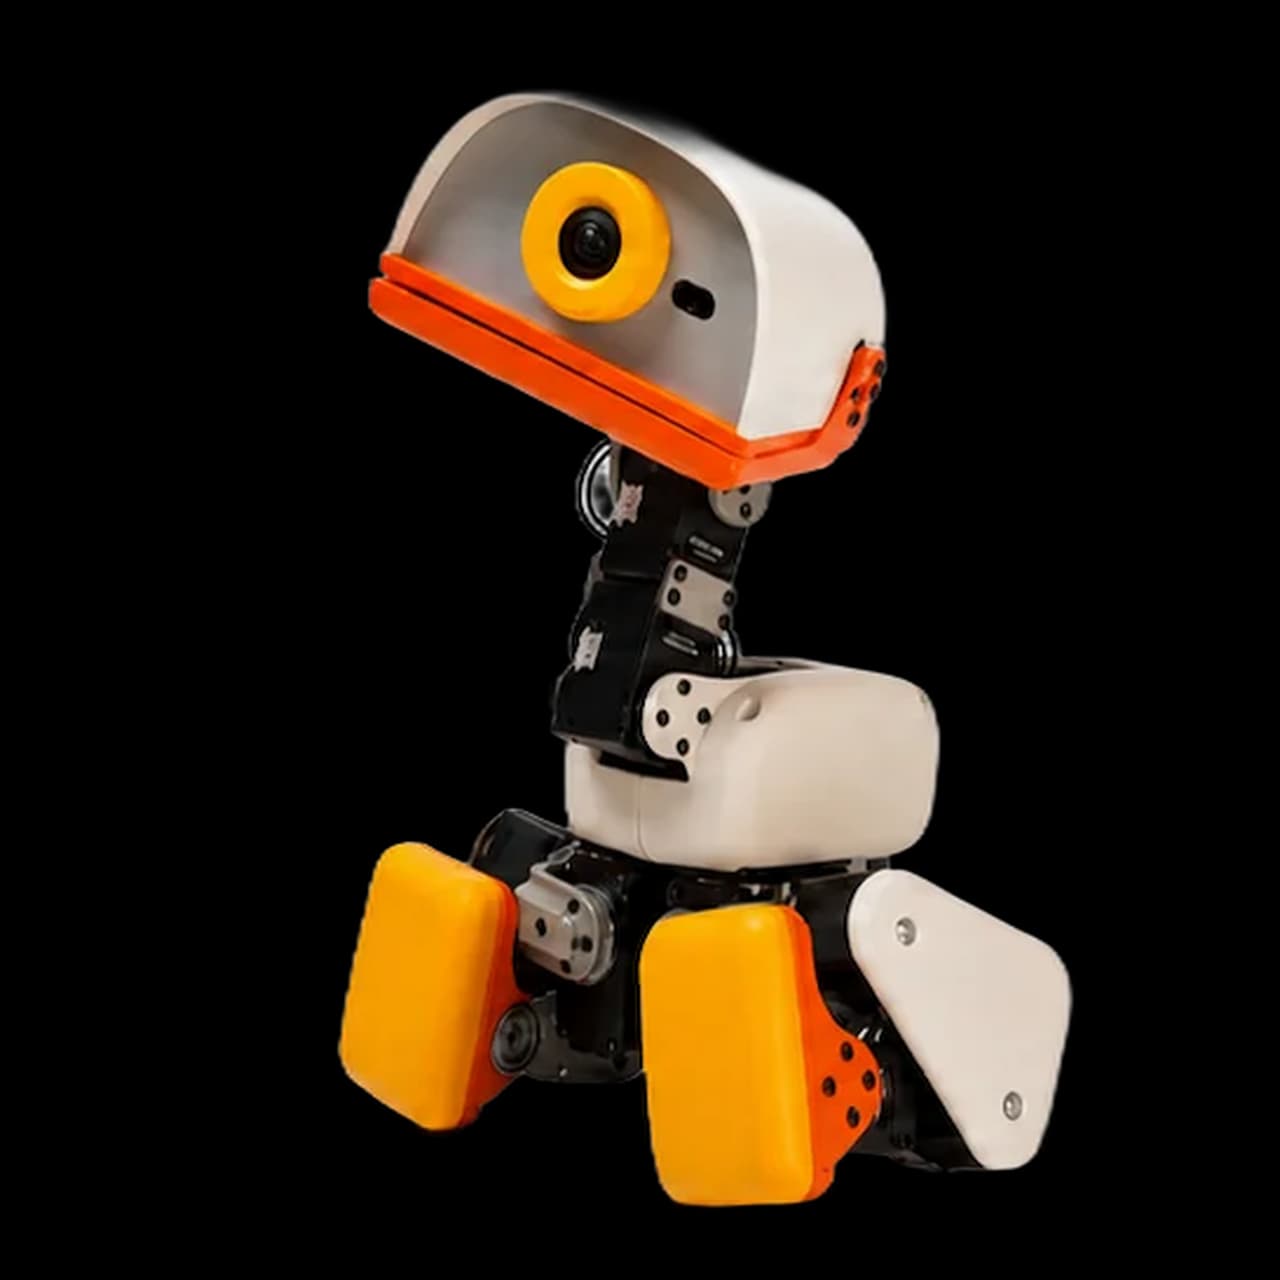
Microduck is a small bipedal robot from Pollen Robotics, about 800 g and 25 cm tall. Neurorobotics Studio supports it in MuJoCo. The simulator model is not included with this embodiment: download it from Pollen Robotics and add it locally in FEAGI Desktop. The model stays on your computer.
Specifications
- Manufacturer
- Pollen Robotics
- Type
- Bipedal Robot
- Environment
- Simulated
- Category
- MuJoCo Physics Simulator
- Controller
- MuJoCo
- Sensors
- Joint positionJoint velocity
- Actuators
- Position servo
- Connectivity
- ZMQLocal
Getting started
Microduck: bring your own MuJoCo model
Neurorobotics Studio supports Microduck. This embodiment does not include the MuJoCo model.
Pollen Robotics publishes the MJCF descriptions under the Apache License 2.0 and the mesh files under CC BY-NC-SA 4.0. Neurorobotics Studio does not redistribute those files. You download them and add the model on this computer.
Get the model
- Clone the model repository: https://github.com/pollen-robotics/microduck_rl
- Use the entry file
src/mjlab_microduck/robot/microduck/scene.xml. - Leave that file in place. It includes other XML files and the mesh files next to it. Moving only
scene.xmlwill not load.
Other
scene_*.xml files in that same folder are task-specific scenes. Start with scene.xml.Add it in FEAGI Desktop
- Open Embodiment Explorer.
- Open the MuJoCo category.
- Select Add local model.
- Choose
scene.xmlfrom the cloned repository. - The model stays on this computer. It is not uploaded to Neurorobotics Studio.
When you start Add local model from the Microduck entry, Desktop names that local model Microduck.
View marketplace for this embodiment · Back to embodiment explorer