SO-ARM100
by The Robot Studio
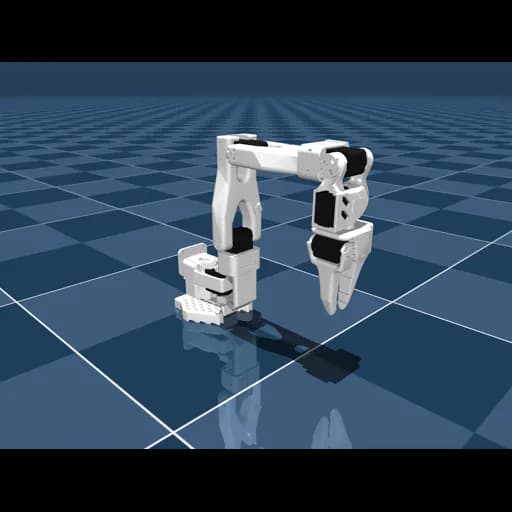
SO-ARM100 is a MuJoCo Menagerie model by The Robot Studio. This embodiment packages the original model assets for use in Neurorobotics Studio. License: Apache-2.0.
Specifications
- Manufacturer
- The Robot Studio
- Type
- Robotic Arm
- Environment
- Simulated
- Category
- MuJoCo Physics Simulator
- Controller
- MuJoCo
- Sensors
- Joint positionJoint velocityBody state
- Actuators
- Position servoTorque control
- Connectivity
- ZMQLocal
View marketplace for this embodiment · Back to embodiment explorer